 The A.I. Daily
Issue 2026-09-23 · Industry · 研究 · 开源 · 应用
NVIDIA details Warp and MjWarp for robot simulation
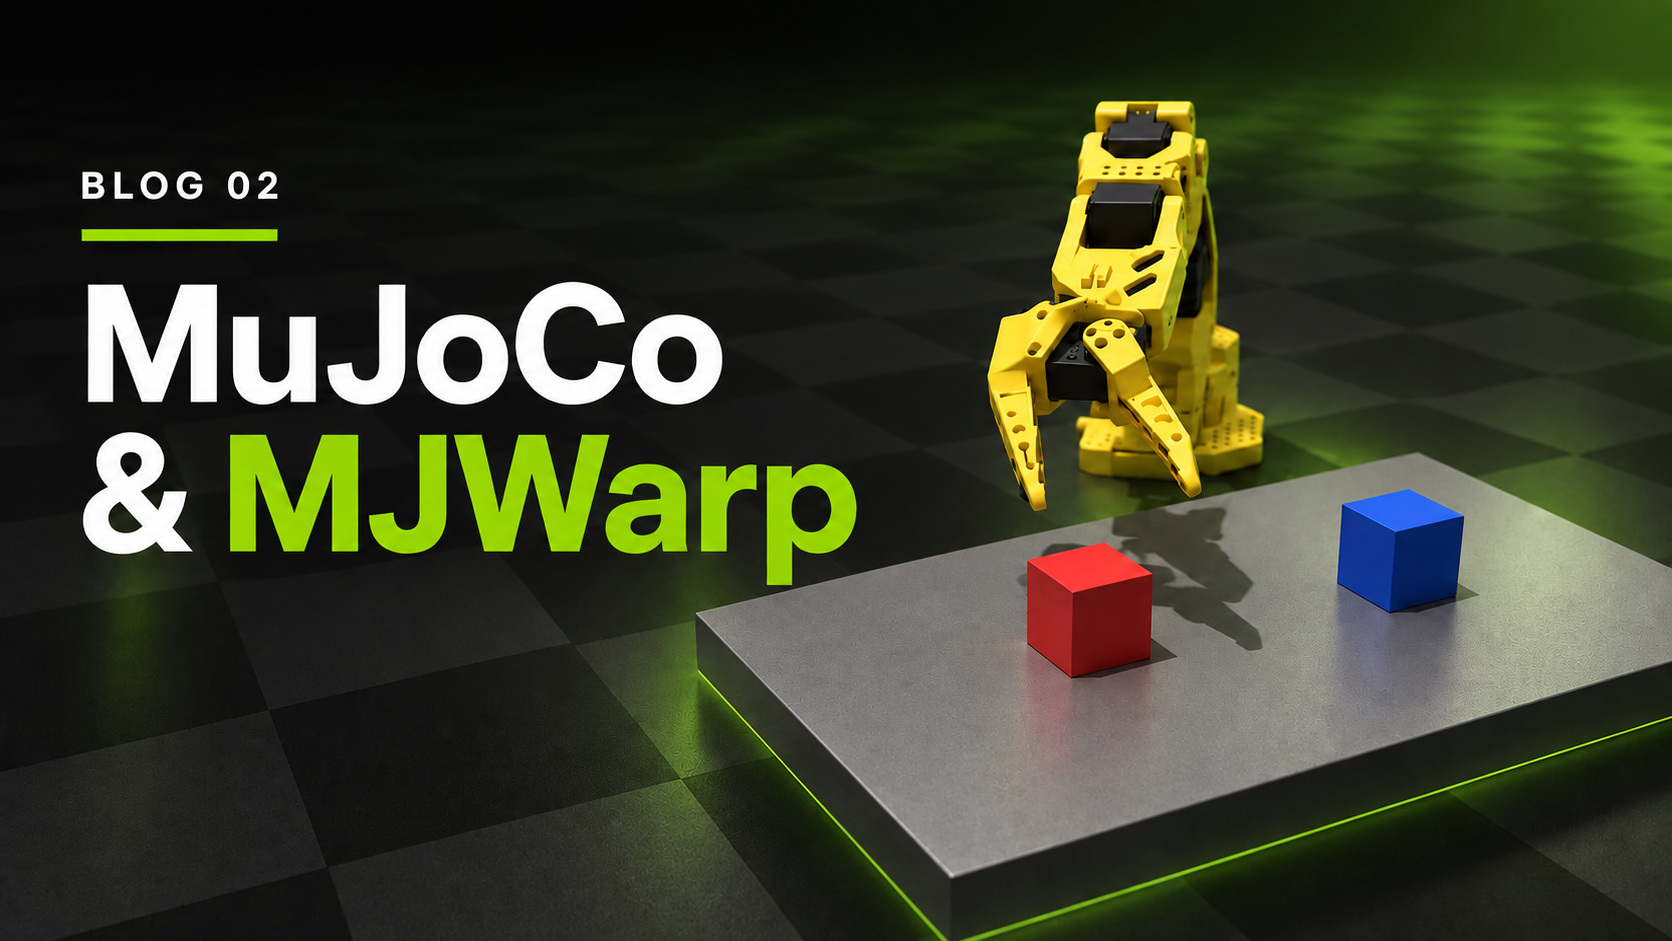
NVIDIA explains how MuJoCo Warp (MJWarp), built on Warp, scales compatible MuJoCo models to as many as 2,048 parallel GPU environments to speed up robot simulation and learning. Using an SO-101 arm, it walks through the technology and validation steps for moving from CPU workflows to GPU scale, as the second part of its Physical AI simulation series.
Read original ↗